First DANUBIS Outdoor Flight Test
Objective
First outdoor flight test of the DANUBIS Operator Console with a commercially available quadcopter. The test covered the full sequence from detection by a stationary camera to inspection of a point of interest (POI) from the air and on the ground.
Flight and control
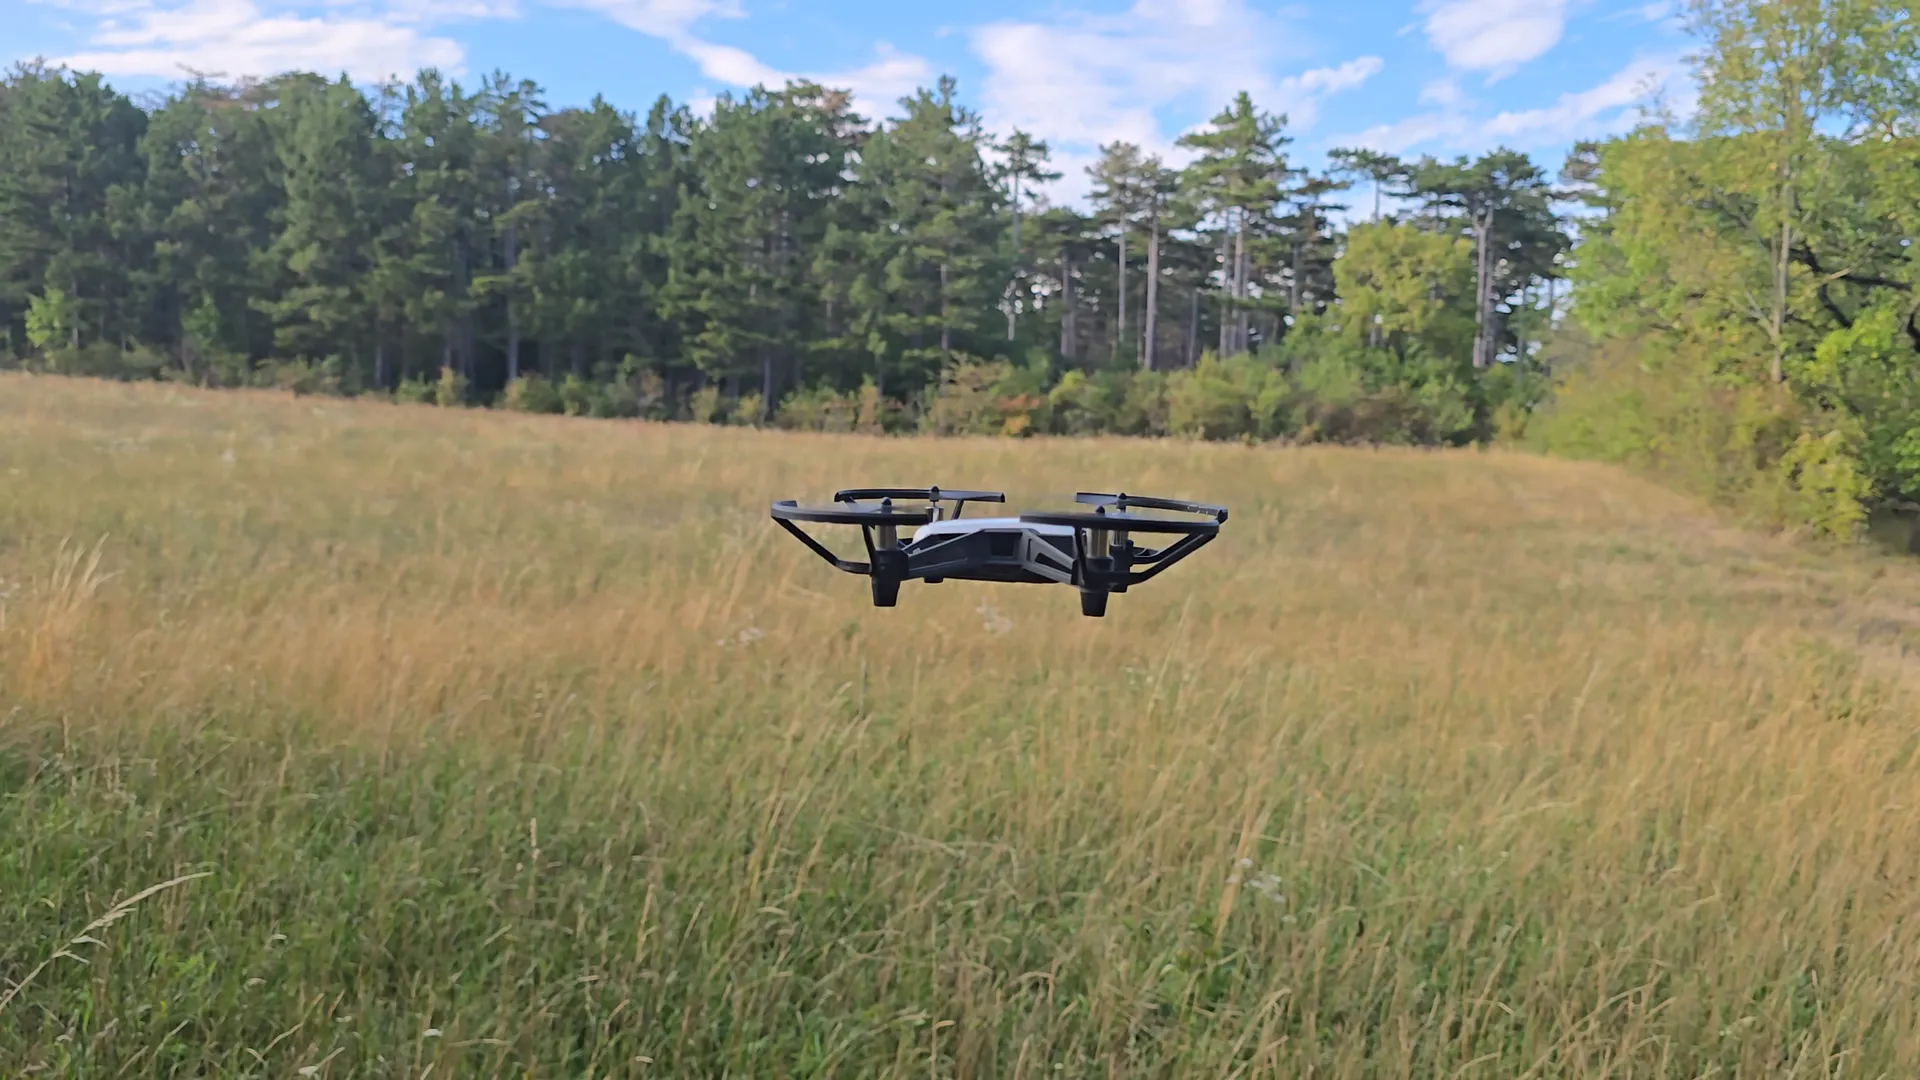
A real quadcopter was launched and controlled through the DANUBIS Operator Console during the field test. Control commands, failsafe functions and live video transmission were tested with a physical aircraft under real outdoor conditions for the first time.
Detection and POI workflow
An object detected by a stationary camera was automatically created as a point of interest (POI) in DANUBIS. An operator then dispatched the drone to the POI through the platform.
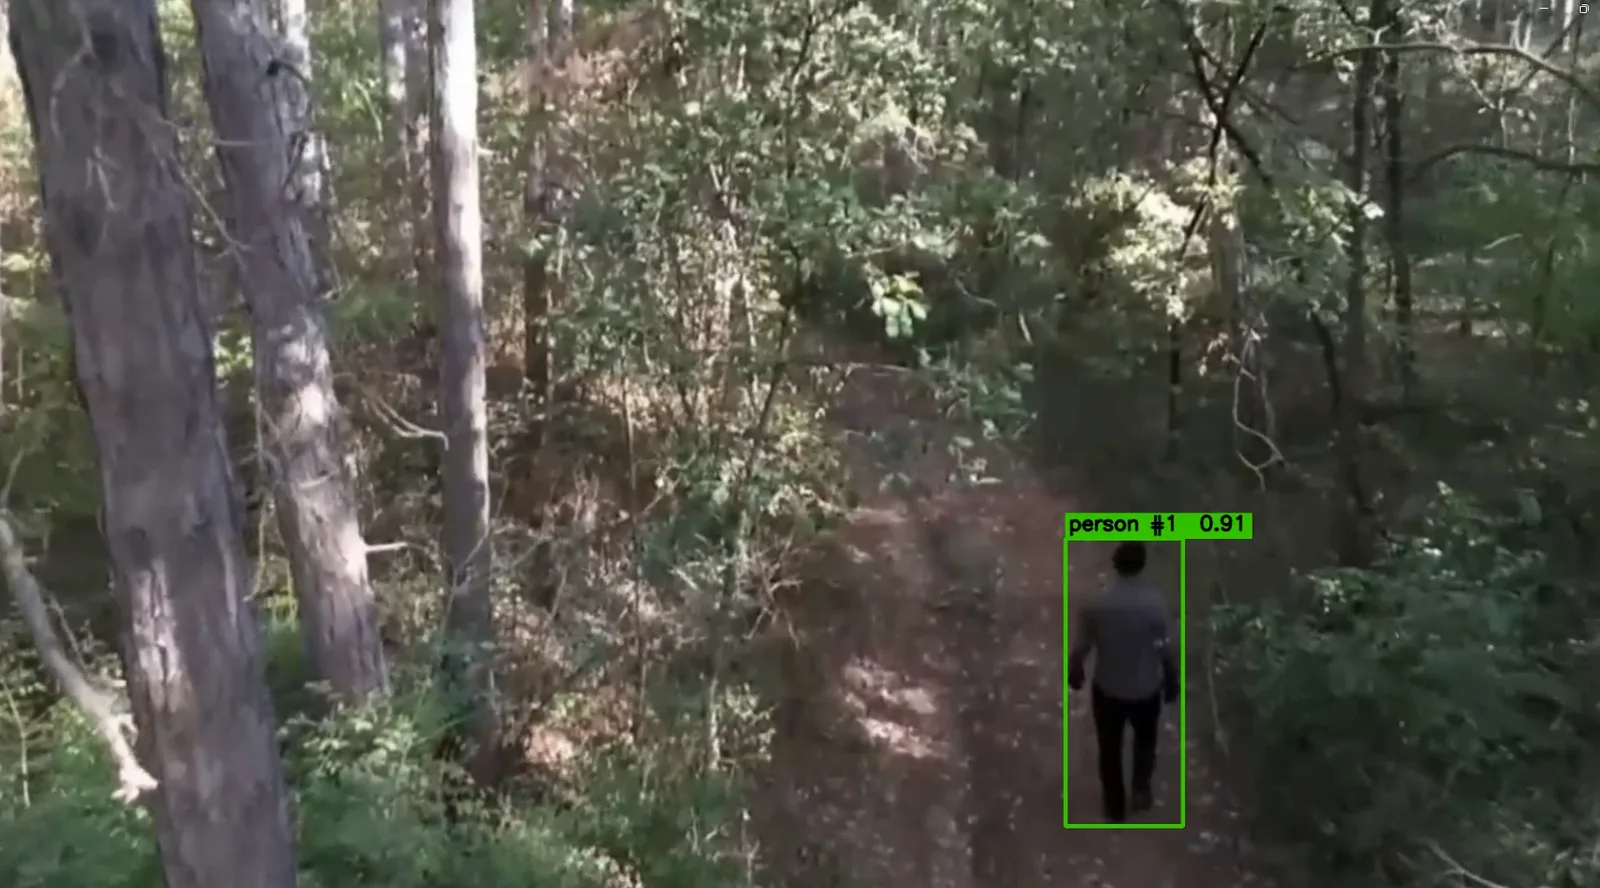
During the flight and while hovering over the target, the drone continuously transmitted live video to the Operator Console. The detection model also detected and tracked the POI in the live drone stream.
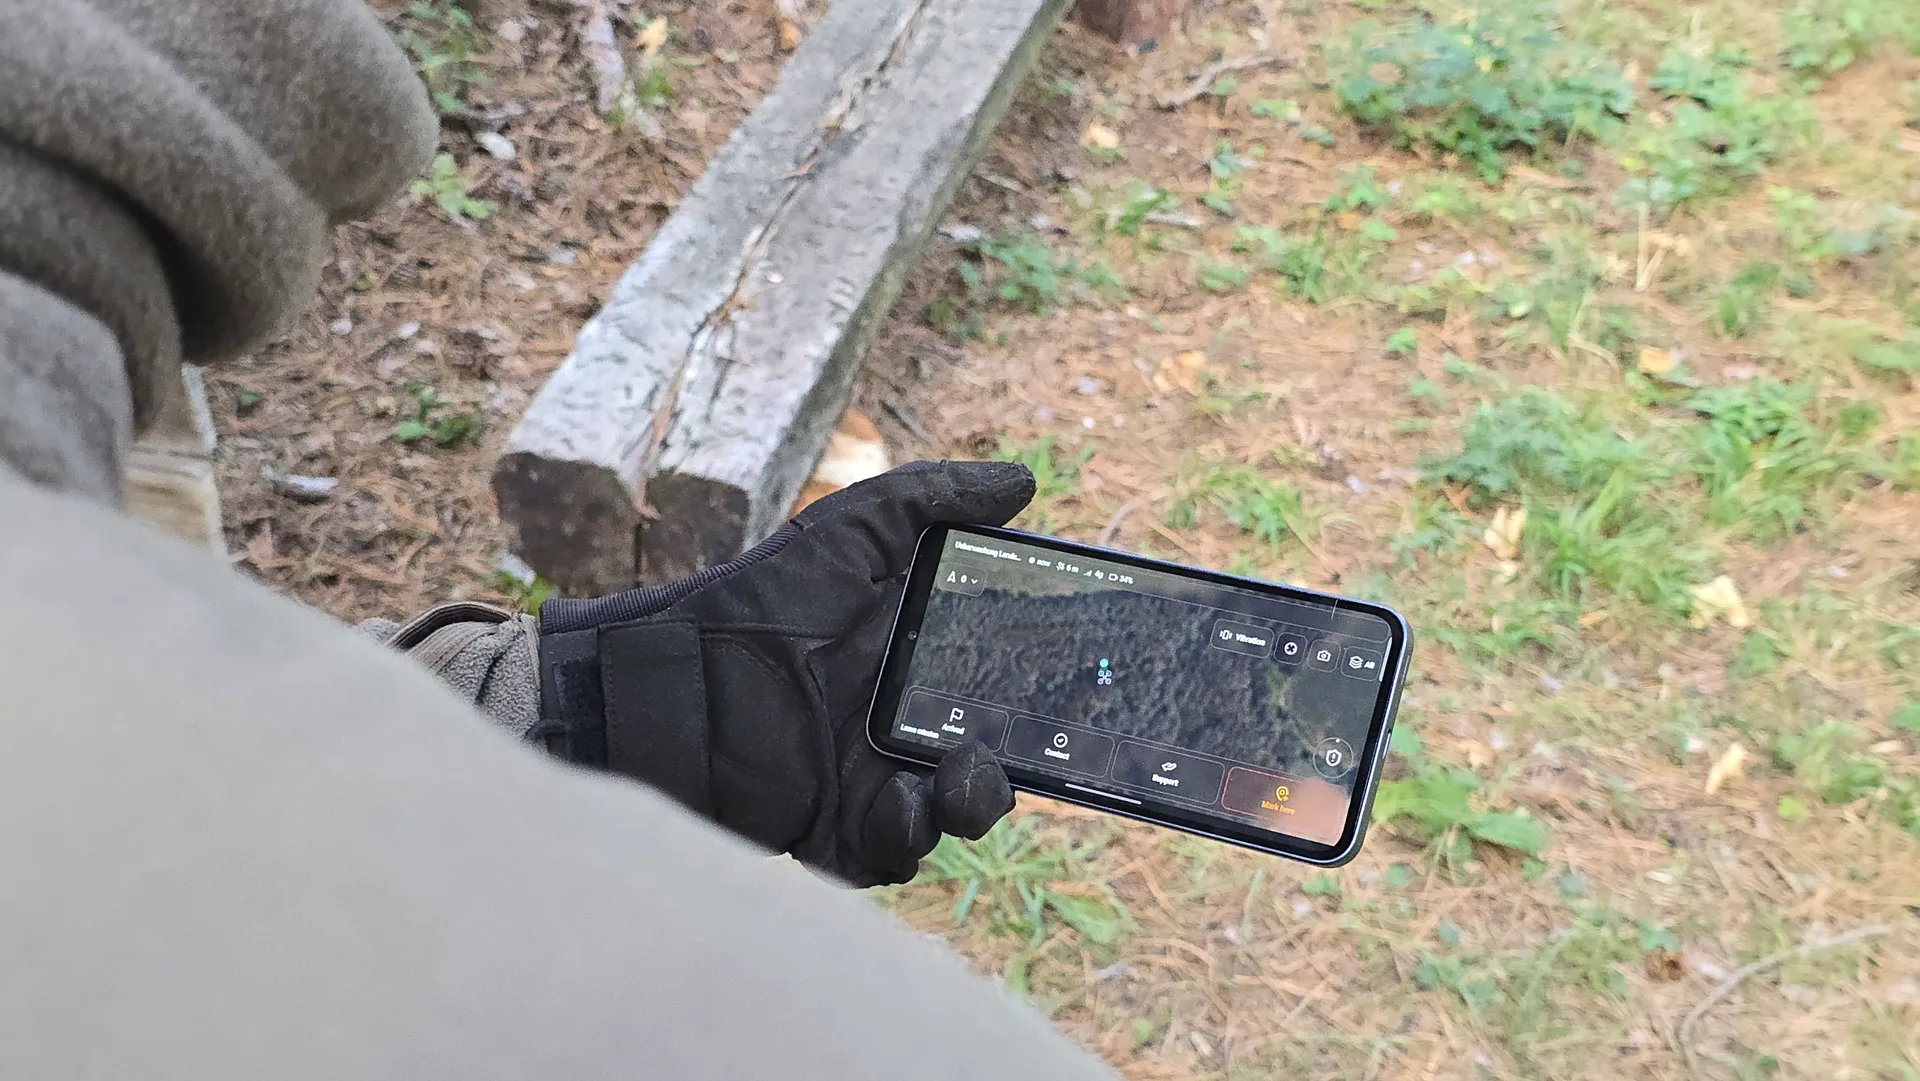
At the same time, a field operator was dispatched to the POI to inspect the target on site. The field operator used the Operator Console in Handheld Mode and communicated with the stationary operator through it. This also tested the handoff of a digitally detected event to a responder in the field within the same workflow.
The field test was the first to cover a continuous operational sequence across multiple sensors, assets and operator roles:
Stationary detection → POI creation → Operator tasking → Drone flight → Live video → Detection and tracking in aerial video → Field operator dispatch → On-site inspection and communication through Handheld Mode
Result: The field test was completed successfully. DANUBIS has connected stationary object detection, POI management, drone control, live streaming, aerial detection and a field operator into one continuous real-world workflow.
The test covered both the technical integration of a real drone and coordination between the stationary operator, the unmanned aircraft and the field responder through a shared platform.
Validated functions
- Launch and control of a real quadcopter through the DANUBIS Operator Console
- Failsafe functions during real flight operations
- Live drone video stream within the platform
- Object detection by a stationary camera and automatic creation of a POI
- Dispatch of the drone to a POI
- Hover over the target
- Detection and tracking of the POI in the live drone stream
- Dispatch of a field operator to the POI
- Use of the Operator Console in Handheld Mode
- Communication between the stationary operator and field operator through DANUBIS
- On-site inspection of a previously detected POI
- Continuous workflow from initial detection to aerial and ground verification