Mission Control
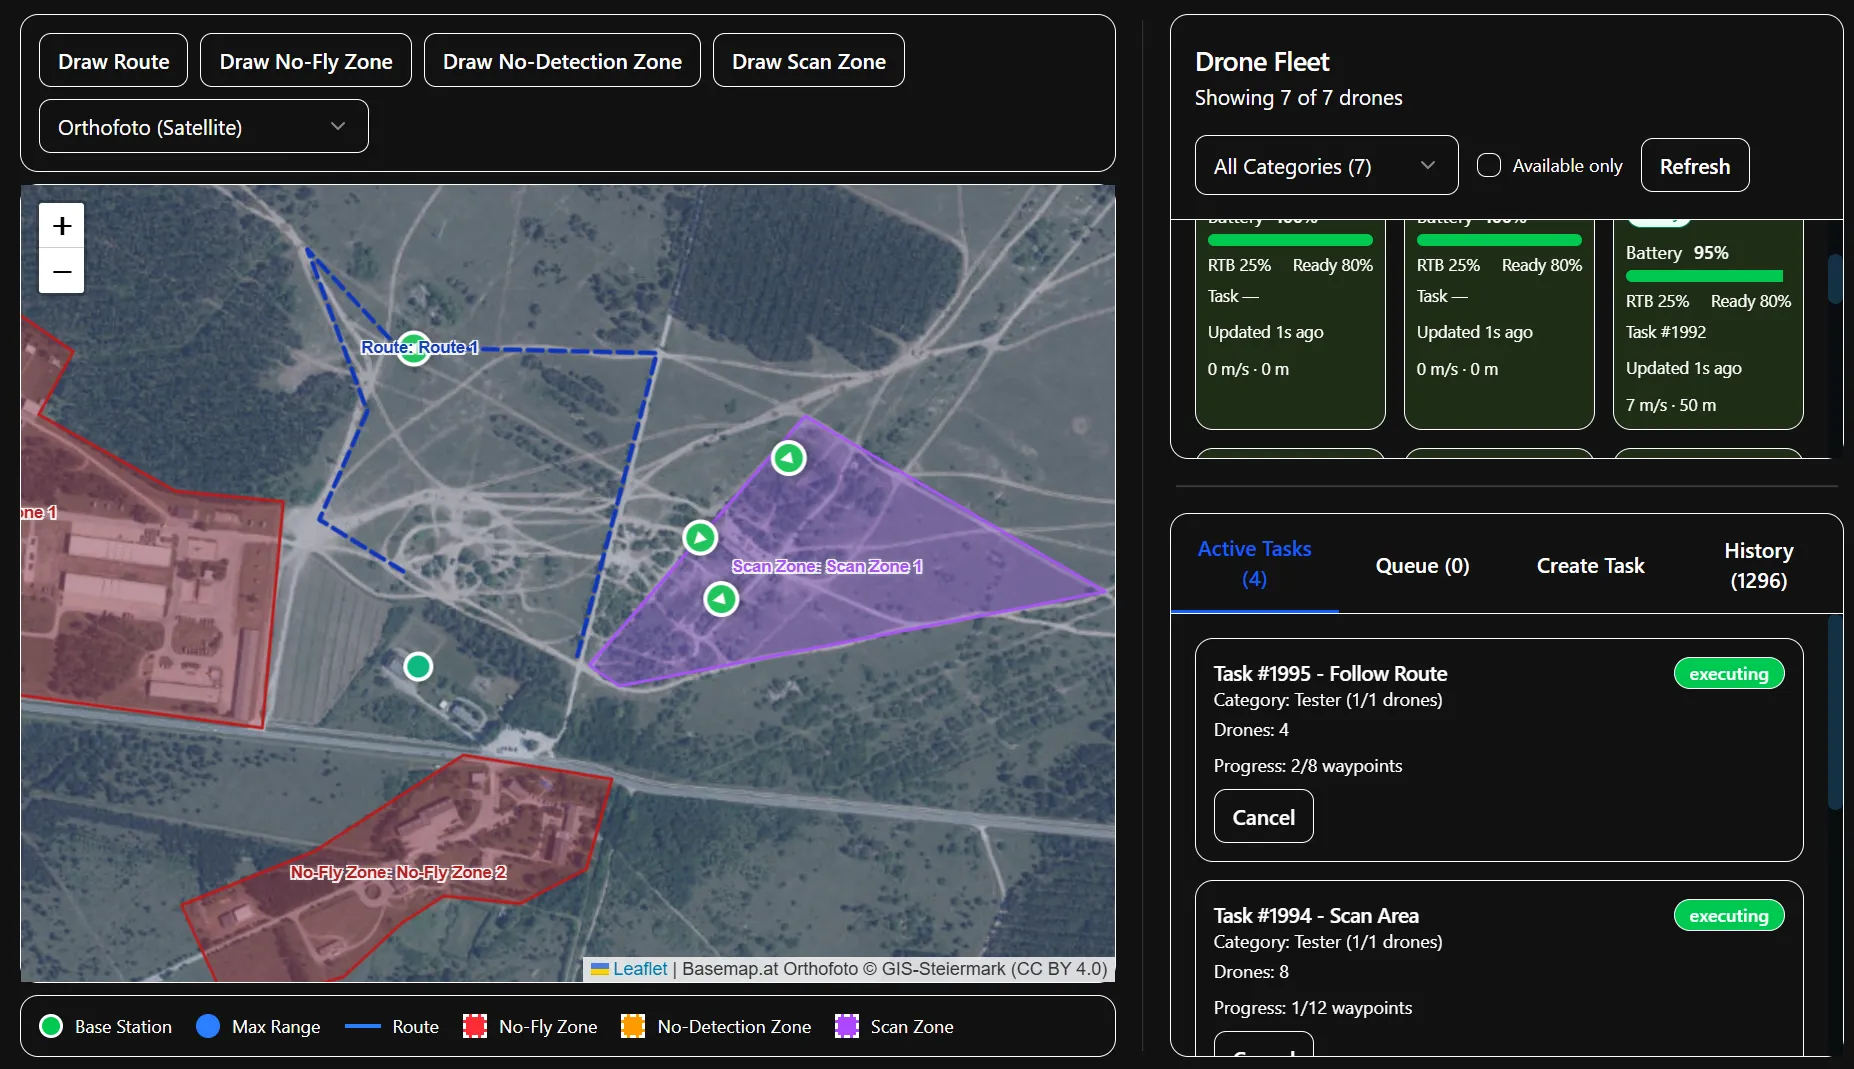
Routes, zones and waypoints are placed directly on the tactical map. No-fly and search zones belong to the mission definition. A mission that would violate a no-fly zone is flagged before launch.
- Routes and waypoints, placed manually or generated as area coverage
- Zones for no-fly, search and detection, part of the mission definition
- Pre-launch checks against regulatory and infrastructure map layers
- Several devices, tasks distributed, rotation and return planned in
Overwatch
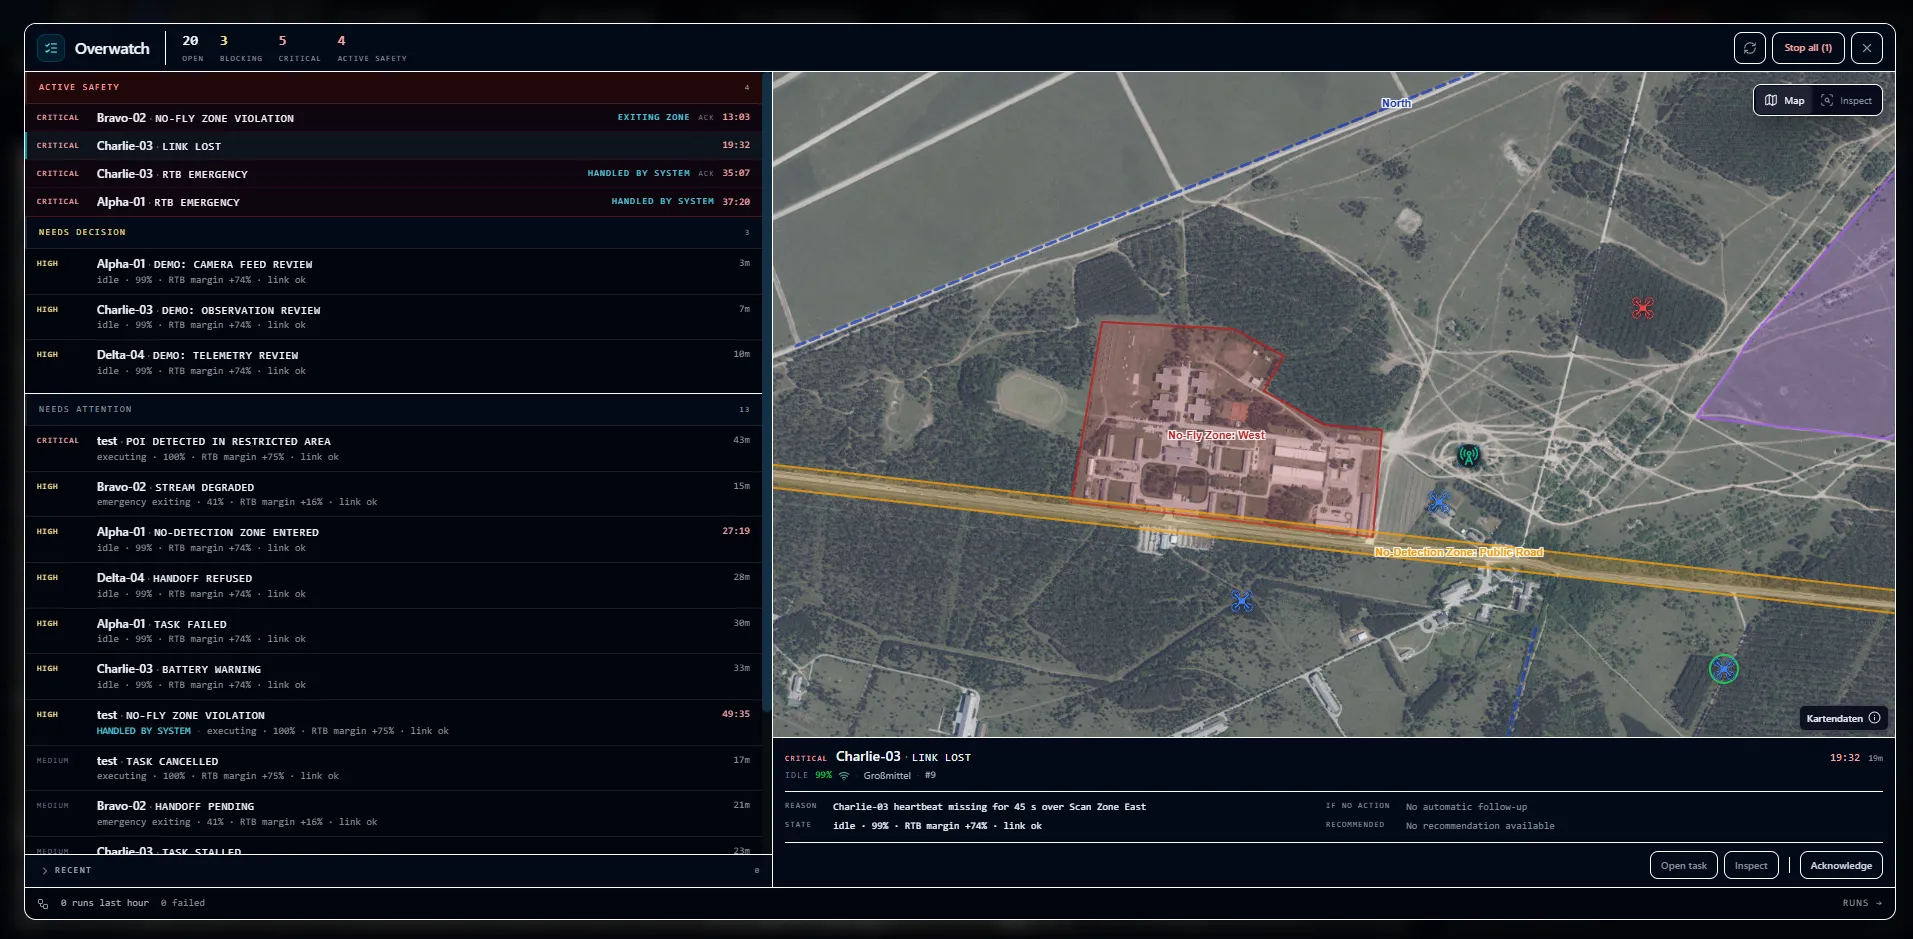
During the mission the console shows progress, condition and cues in real time. Critical steps are put to the operator and wait for a decision.
- Approvals for mission-critical actions, granted individually
- Escalation of rejected and pending approvals
- Intervention at any time, manual takeover from automatic operation
- Operating states from the real data flow
Station and field
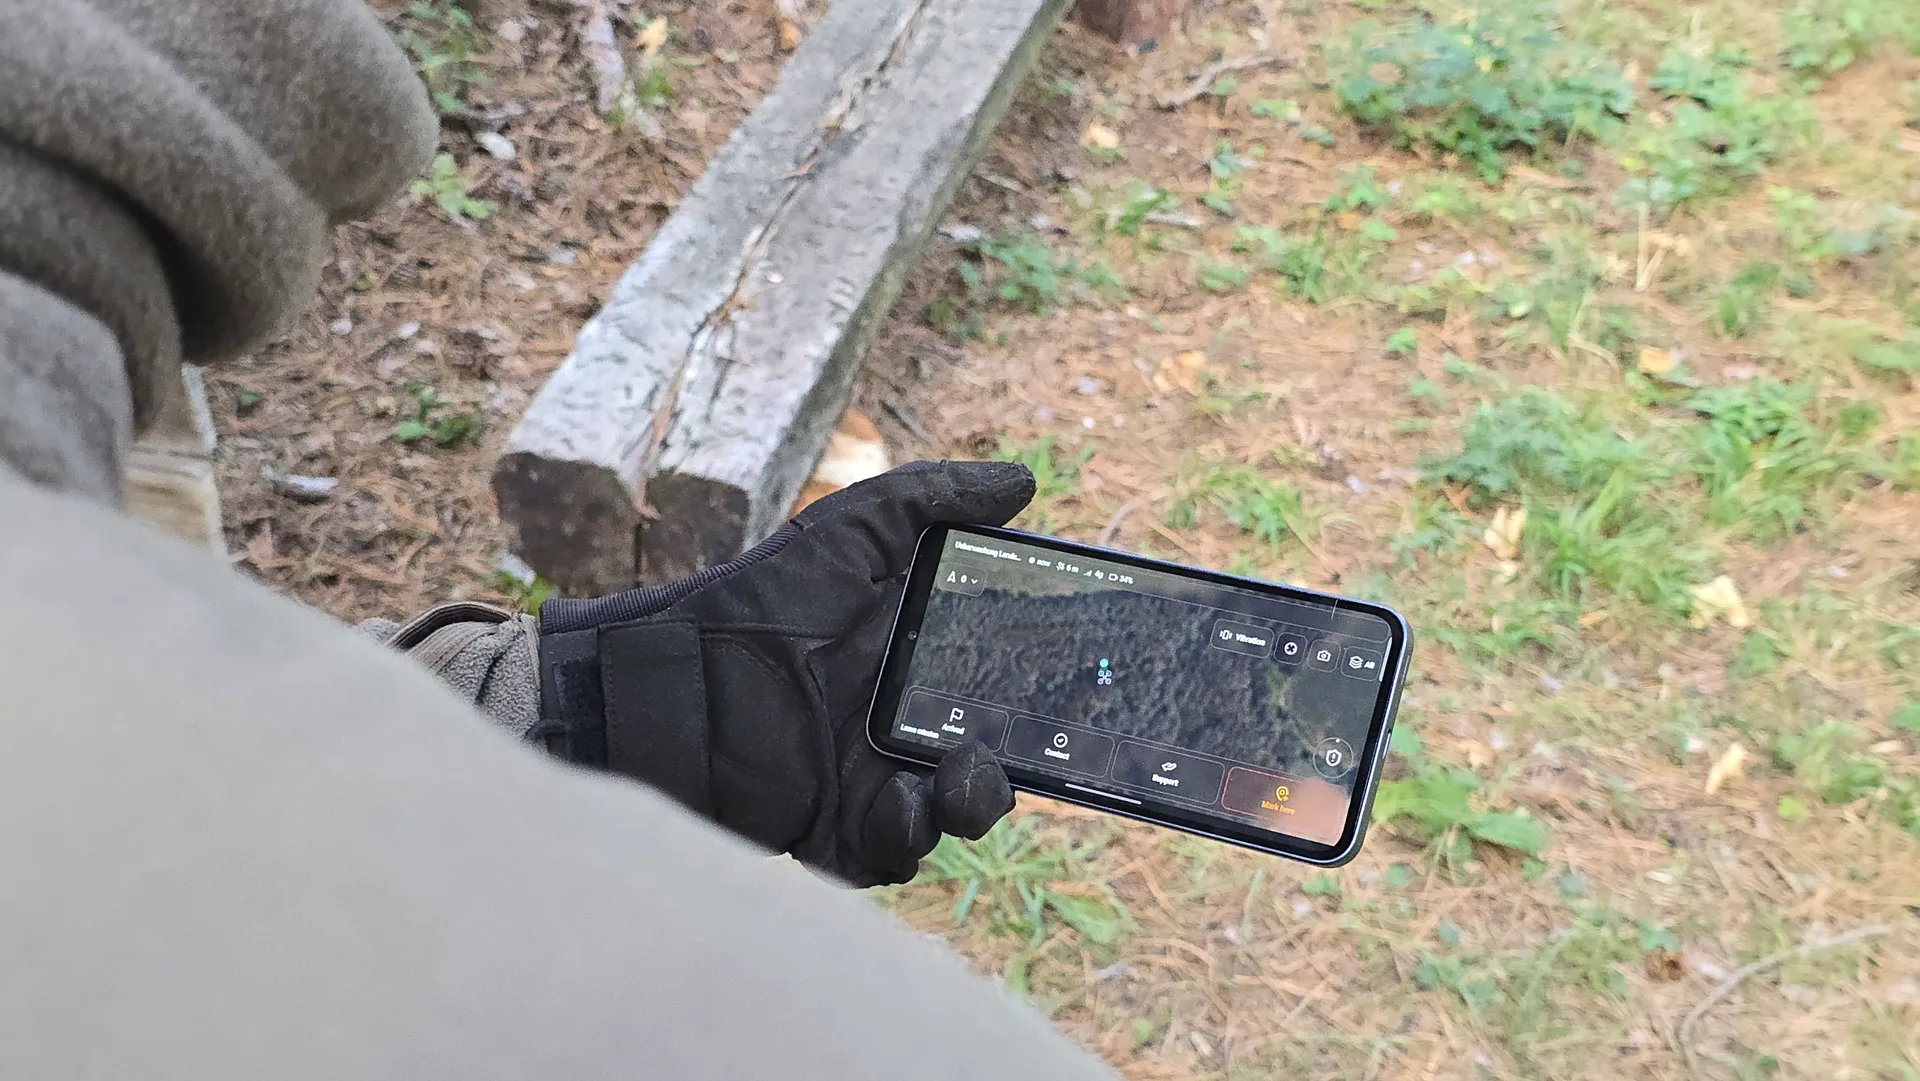
The station operator commands from the field station. The field operator works on the move. Both see the same data.
- Station operator, full planning and command at the field station
- Field operator, mobile view in the field, on the local network
- Shared picture, cues and progress immediately visible to both roles
- Access management for devices and roles, revocable at any time
Mission Review
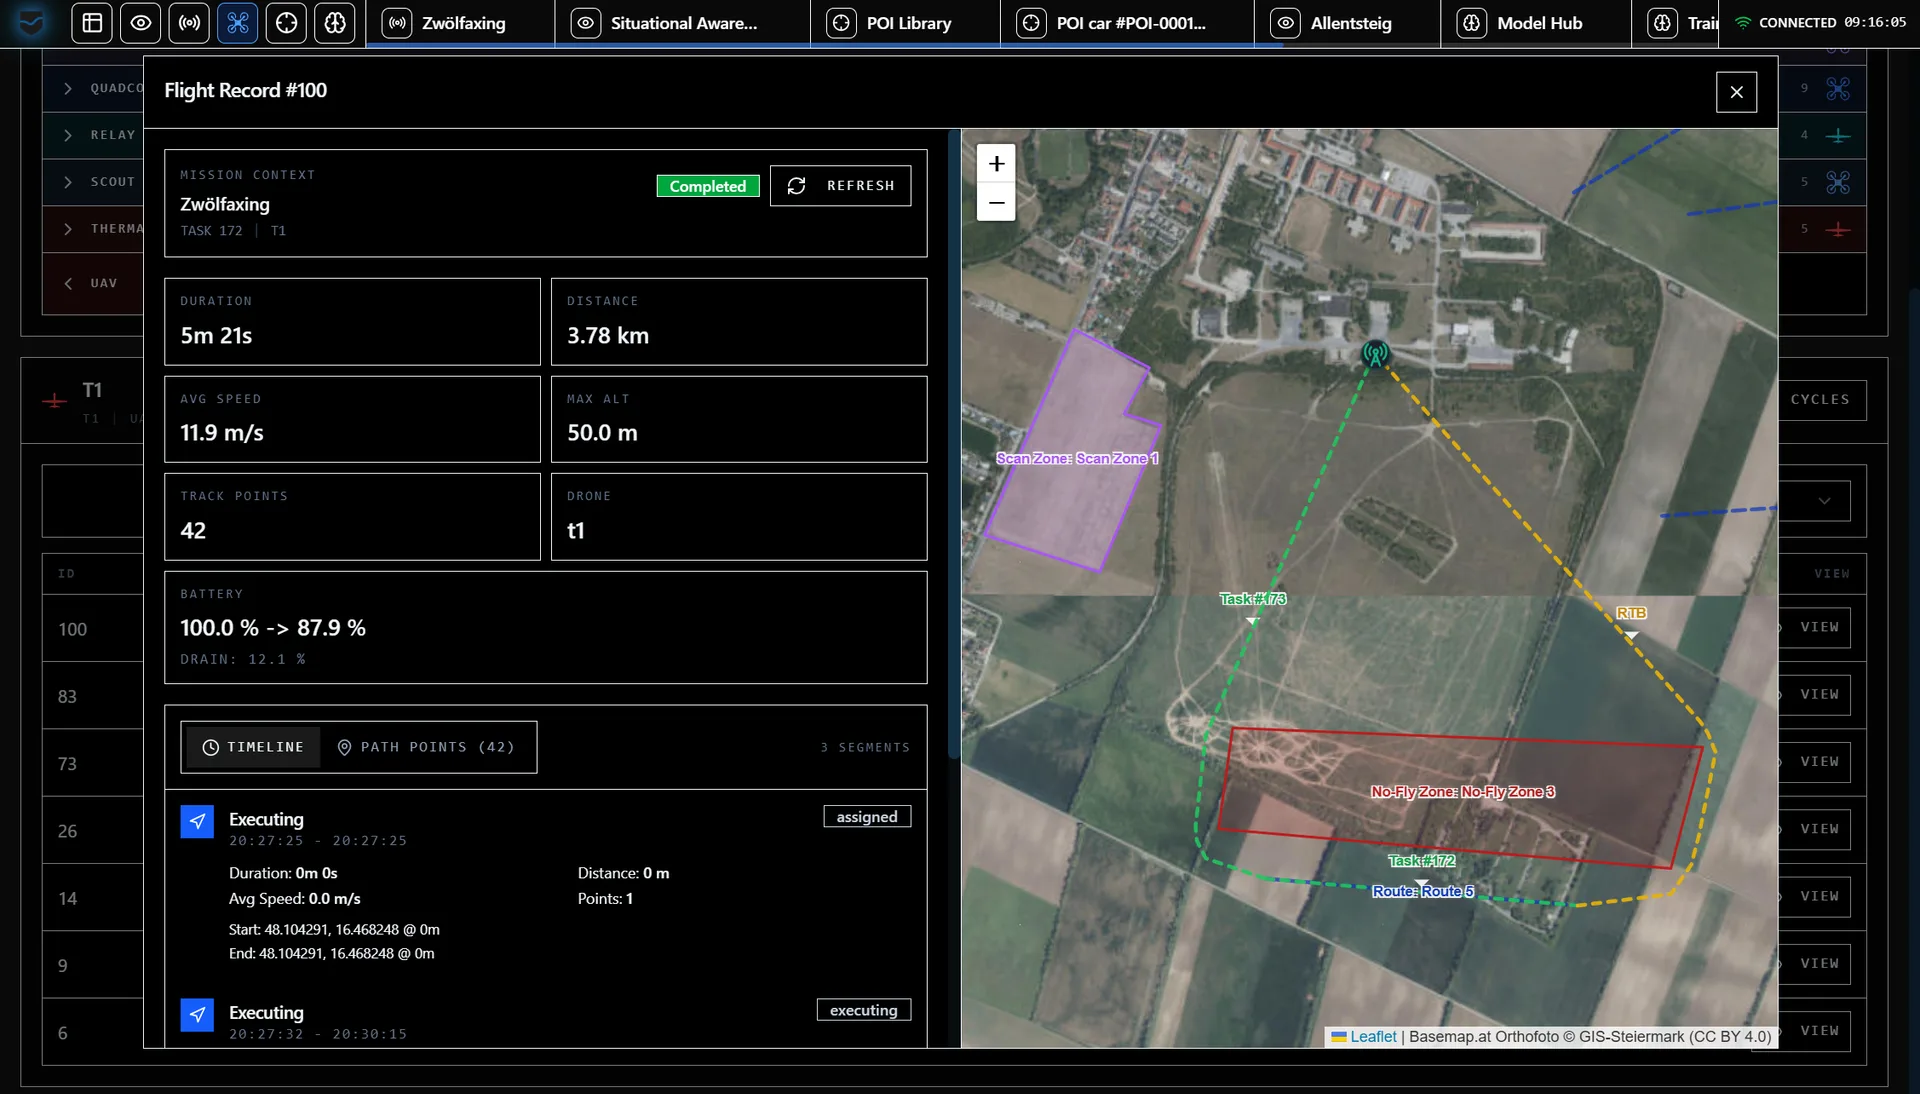
After the mission it can be walked through again: recording, track and detections brought together on one timeline. Recording sessions carry a continuous integrity check. Gaps and deviations are reported.
- Playback of recording, position and detections, in sync
- Integrity, an unbroken chain per session, deviations are reported
- Retention per session, with advance notice and the ability to hold
- Handover, export for exploitation and evidentiary use outside the system
See mission command in operation
On-site demonstrations in Austria are available, using your own scenarios.
Request a demonstration