02
MAVLink Proof of Concept
Objective
Demonstration of end-to-end MAVLink integration in the Danubis platform using MAVLink software-in-the-loop (SITL) simulation.
Summary
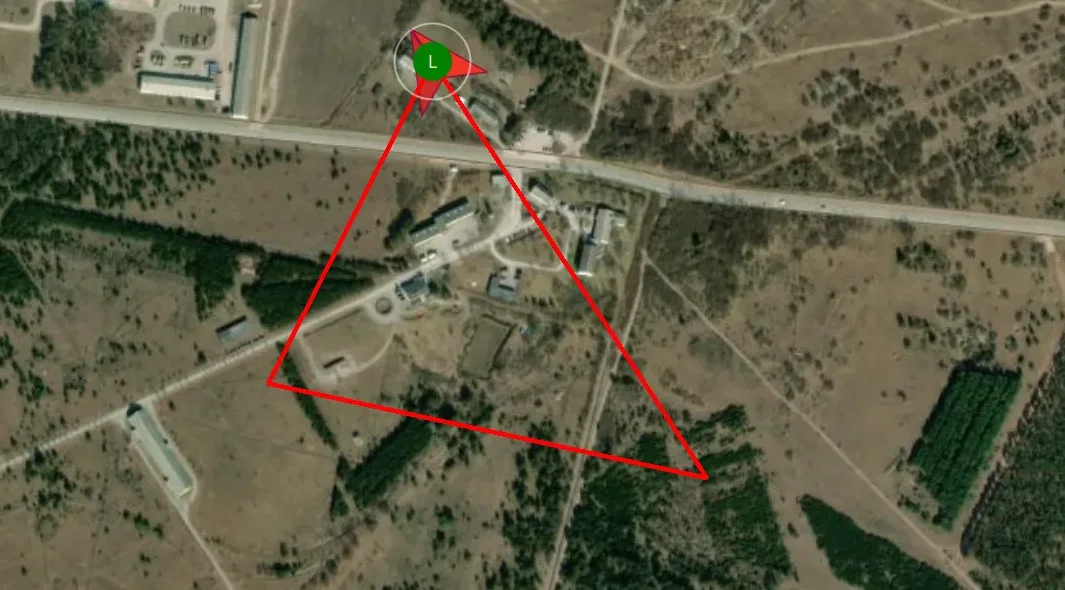
Proof of concept of the complete MAVLink command chain using ArduPilot software-in-the-loop (SITL) simulation. The integration is embedded directly in the platform's production mission path. QGroundControl served as an independent external validation instance.
Result: PoC completed successfully. The end-to-end functionality of the MAVLink command chain is demonstrated. The platform operates in a standards-compliant and vendor-independent manner.
Validated functions
- Arm/disarm, takeoff, landing and emergency stop
- Waypoint navigation and return-to-home (RTL)
- Real-time telemetry (GPS, battery, heading, speed)
- Multi-drone operation with parallel SITL containers
- Automatic reconnect and lifecycle management
